|
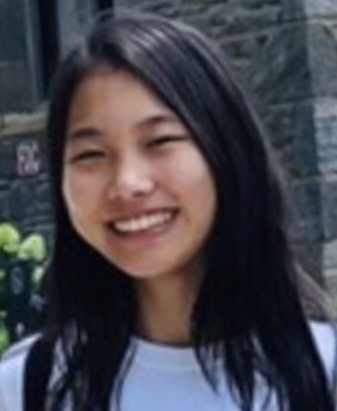
Mimo ShirasakaPhD Student | AI & Robotics I'm a DPhil student in Engineering Science at the University of Oxford, advised by Prof. Ingmar Posner at the Applied Artificial Intelligence Lab in the Oxford Robotics Institute. I received my B.E. from the University of Tokyo (UTokyo) in March 2026, where I was advised by Prof. Jun Ota. I also work closely with Prof. Yoichi Sato in the Computer Vision Group at UTokyo, and have been fortunate to be mentored by Prof. Yonatan Bisk at Carnegie Mellon University. Previously, I was a research engineer intern at AIRoA and a research assistant at TRAIL, UTokyo. I also interned at OMRON SINIC X as a researcher and at Mercari as an ML engineer. |
 |
 |
 |
 |
 |
 |
 |
News2026
[Oct 2026] Started my DPhil at Oxford! 2025
[Apr 2025] Joined Ota Lab at UTokyo. 2024
[Jul 2024] Received Best Poster Award at RSS 2024 Workshop! 2023
[Sep 2023] Presented "Self-recovery prompting" at CoRL 2023. |
Publications
|
|
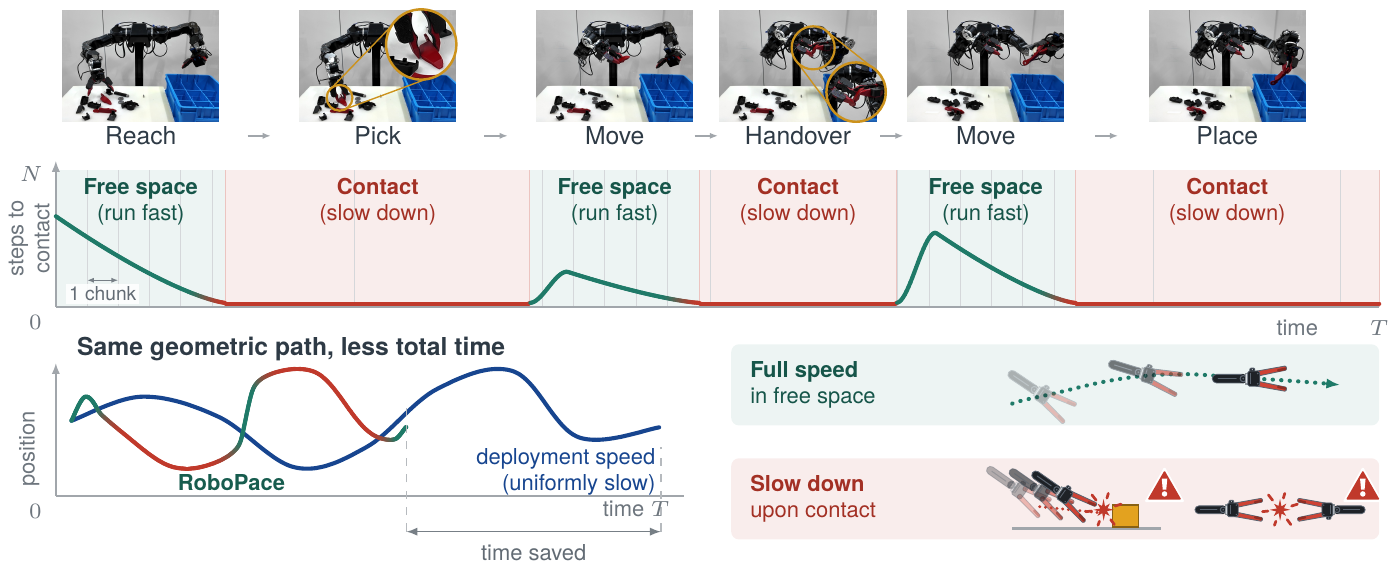
Mimo Shirasaka, Takehiko Ohkawa, Takuya Okubo, Nicola Scianca, Tatsuya Matsushima, and Kei Ota arXiv, 2026 Paper RoboPace automatically retimes a policy's action chunks online, speeding up in free space and slowing down at predicted contact to achieve both safety and efficiency. |
|
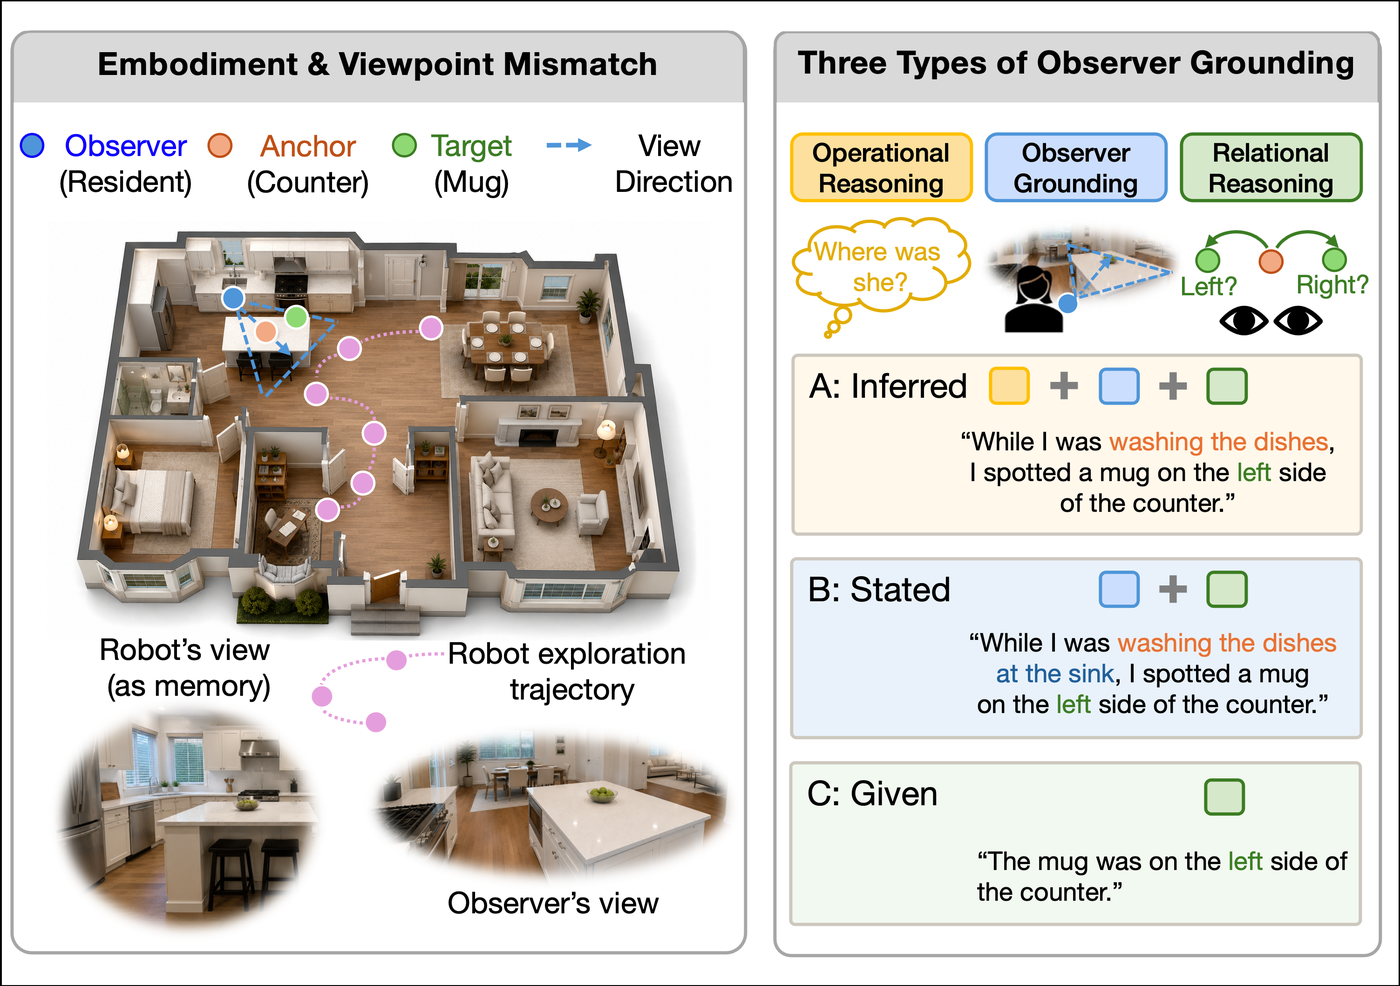
Mimo Shirasaka, Haochen Zhang, and Yonatan Bisk EMNLP Findings, 2026 Website / Code / Dataset POVBench tests whether VLMs can infer a speaker's viewpoint from contextual cues and localize the object they describe from that viewpoint. |
|
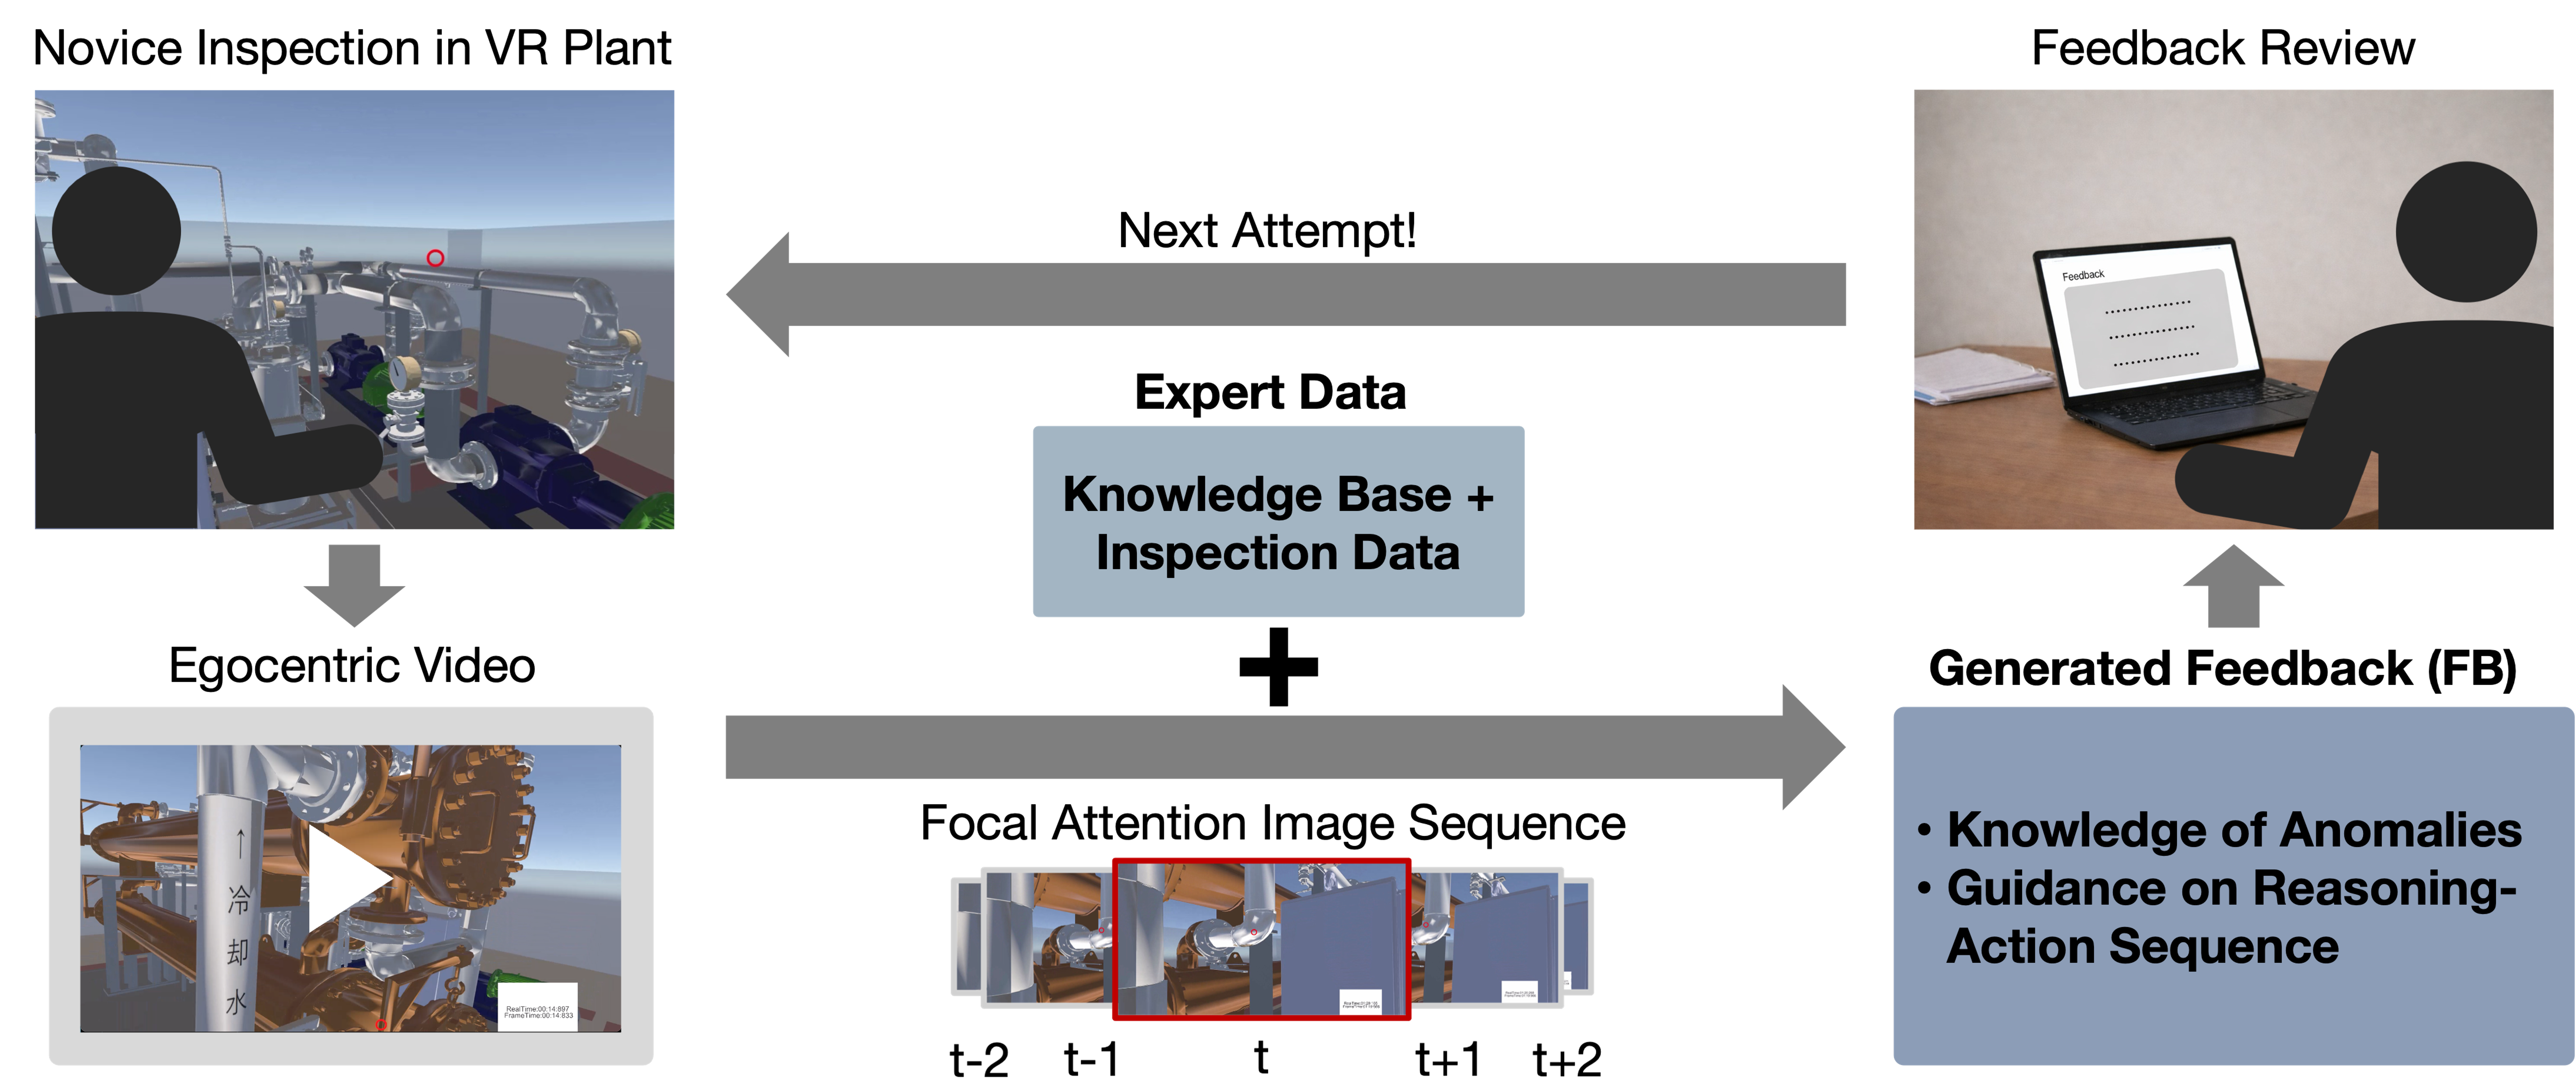
Mimo Shirasaka, Kohei Kaminishi, Shinji Kanda, Yasushi Umeda, Masayoshi Kinoshita, Risa Koda, Shota Shimizu, and Jun Ota Augmented Humans, 2026 Poster and Demo Paper INSIGHT combines VR-based industrial plant inspection with post-task action-reasoning feedback, helping novices learn expert reasoning-action sequences and improve anomaly detection performance. |
|
Mimo Shirasaka, Cristian C. Beltran-Hernandez, Masashi Hamaya, and Yoshitaka Ushiku ICRA, 2026 Paper Combining compliance-enabled contact formation with automated failure recovery makes soft robotic object insertion robust to uncertainty and environmental variation. |
|
|
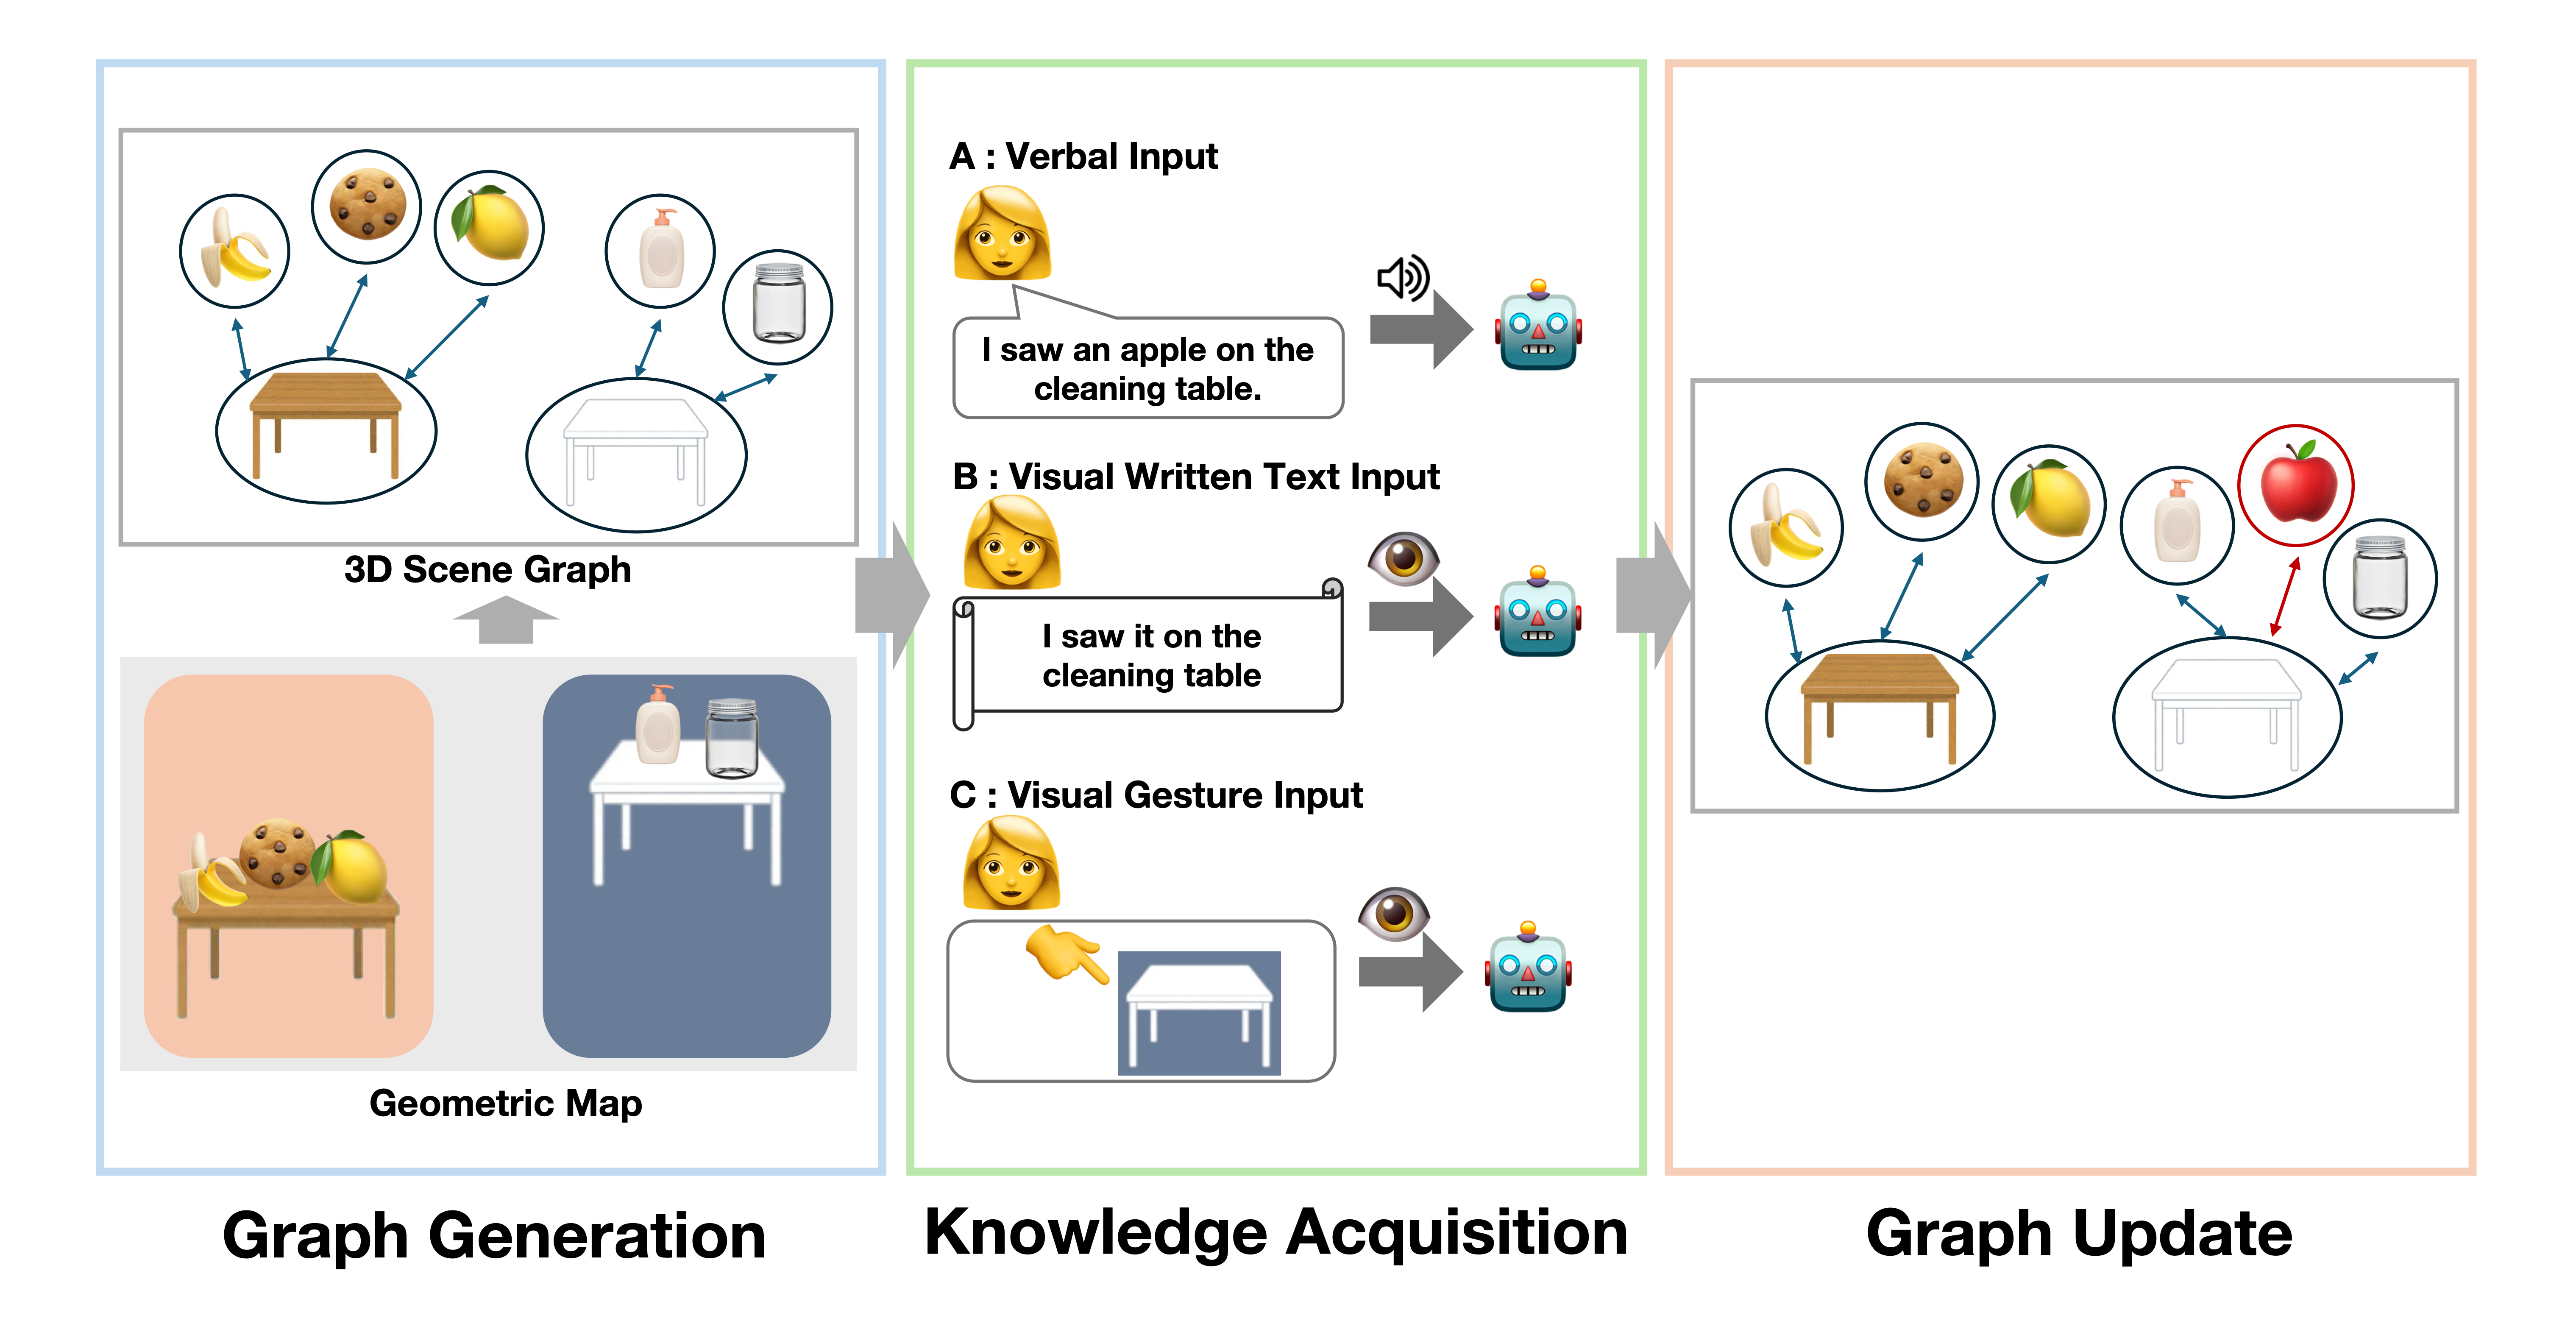
Mimo Shirasaka, Yuya Ikeda, Tatsuya Matsushima, Yutaka Matsuo, and Yusuke Iwasawa RSS Workshop, 2024 Poster — Best Poster Award Paper The SPARK system extracts semantic information from environment cues (verbal, written text, and gesture) and updates the scene graph online for robot task planning. |
|
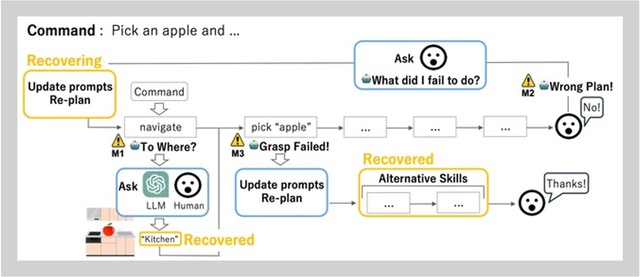
Mimo Shirasaka, Tatsuya Matsushima, Soshi Tsunashima, Yuya Ikeda, Aoi Horo, So Ikoma, Chikaha Tsuji, Hikaru Wada, Tsunekazu Omija, Dai Komukai, Yutaka Matsuo, and Yusuke Iwasawa ICRA, 2024 Oral, Poster, Demo Paper / Website The self-recovery pipeline's automatic prompt updates enable failure recovery and task completion in general-purpose home robot tasks. |
Projects
|
|
Analyzed and visualized large-scale migration data from 2021 to 2024 to reveal how wild birds move south for wintering and return north in spring, as the final project for a data science class. Tech: Python, Matplotlib, Data Organization and Analysis |
|
|
Designed a bilingual (EN/JP) mobile app that generates simple recipes from on-hand ingredients to encourage elderly people with little cooking experience to prepare healthy meals at home. Tech: React Native, Python, FastAPI, OpenAI API, Expo Go |
|
|
Developed a full-stack web app (frontend & backend) for Build@Mercari 2025 final project. Tech: Python, API, SQLite, Docker |
|
|
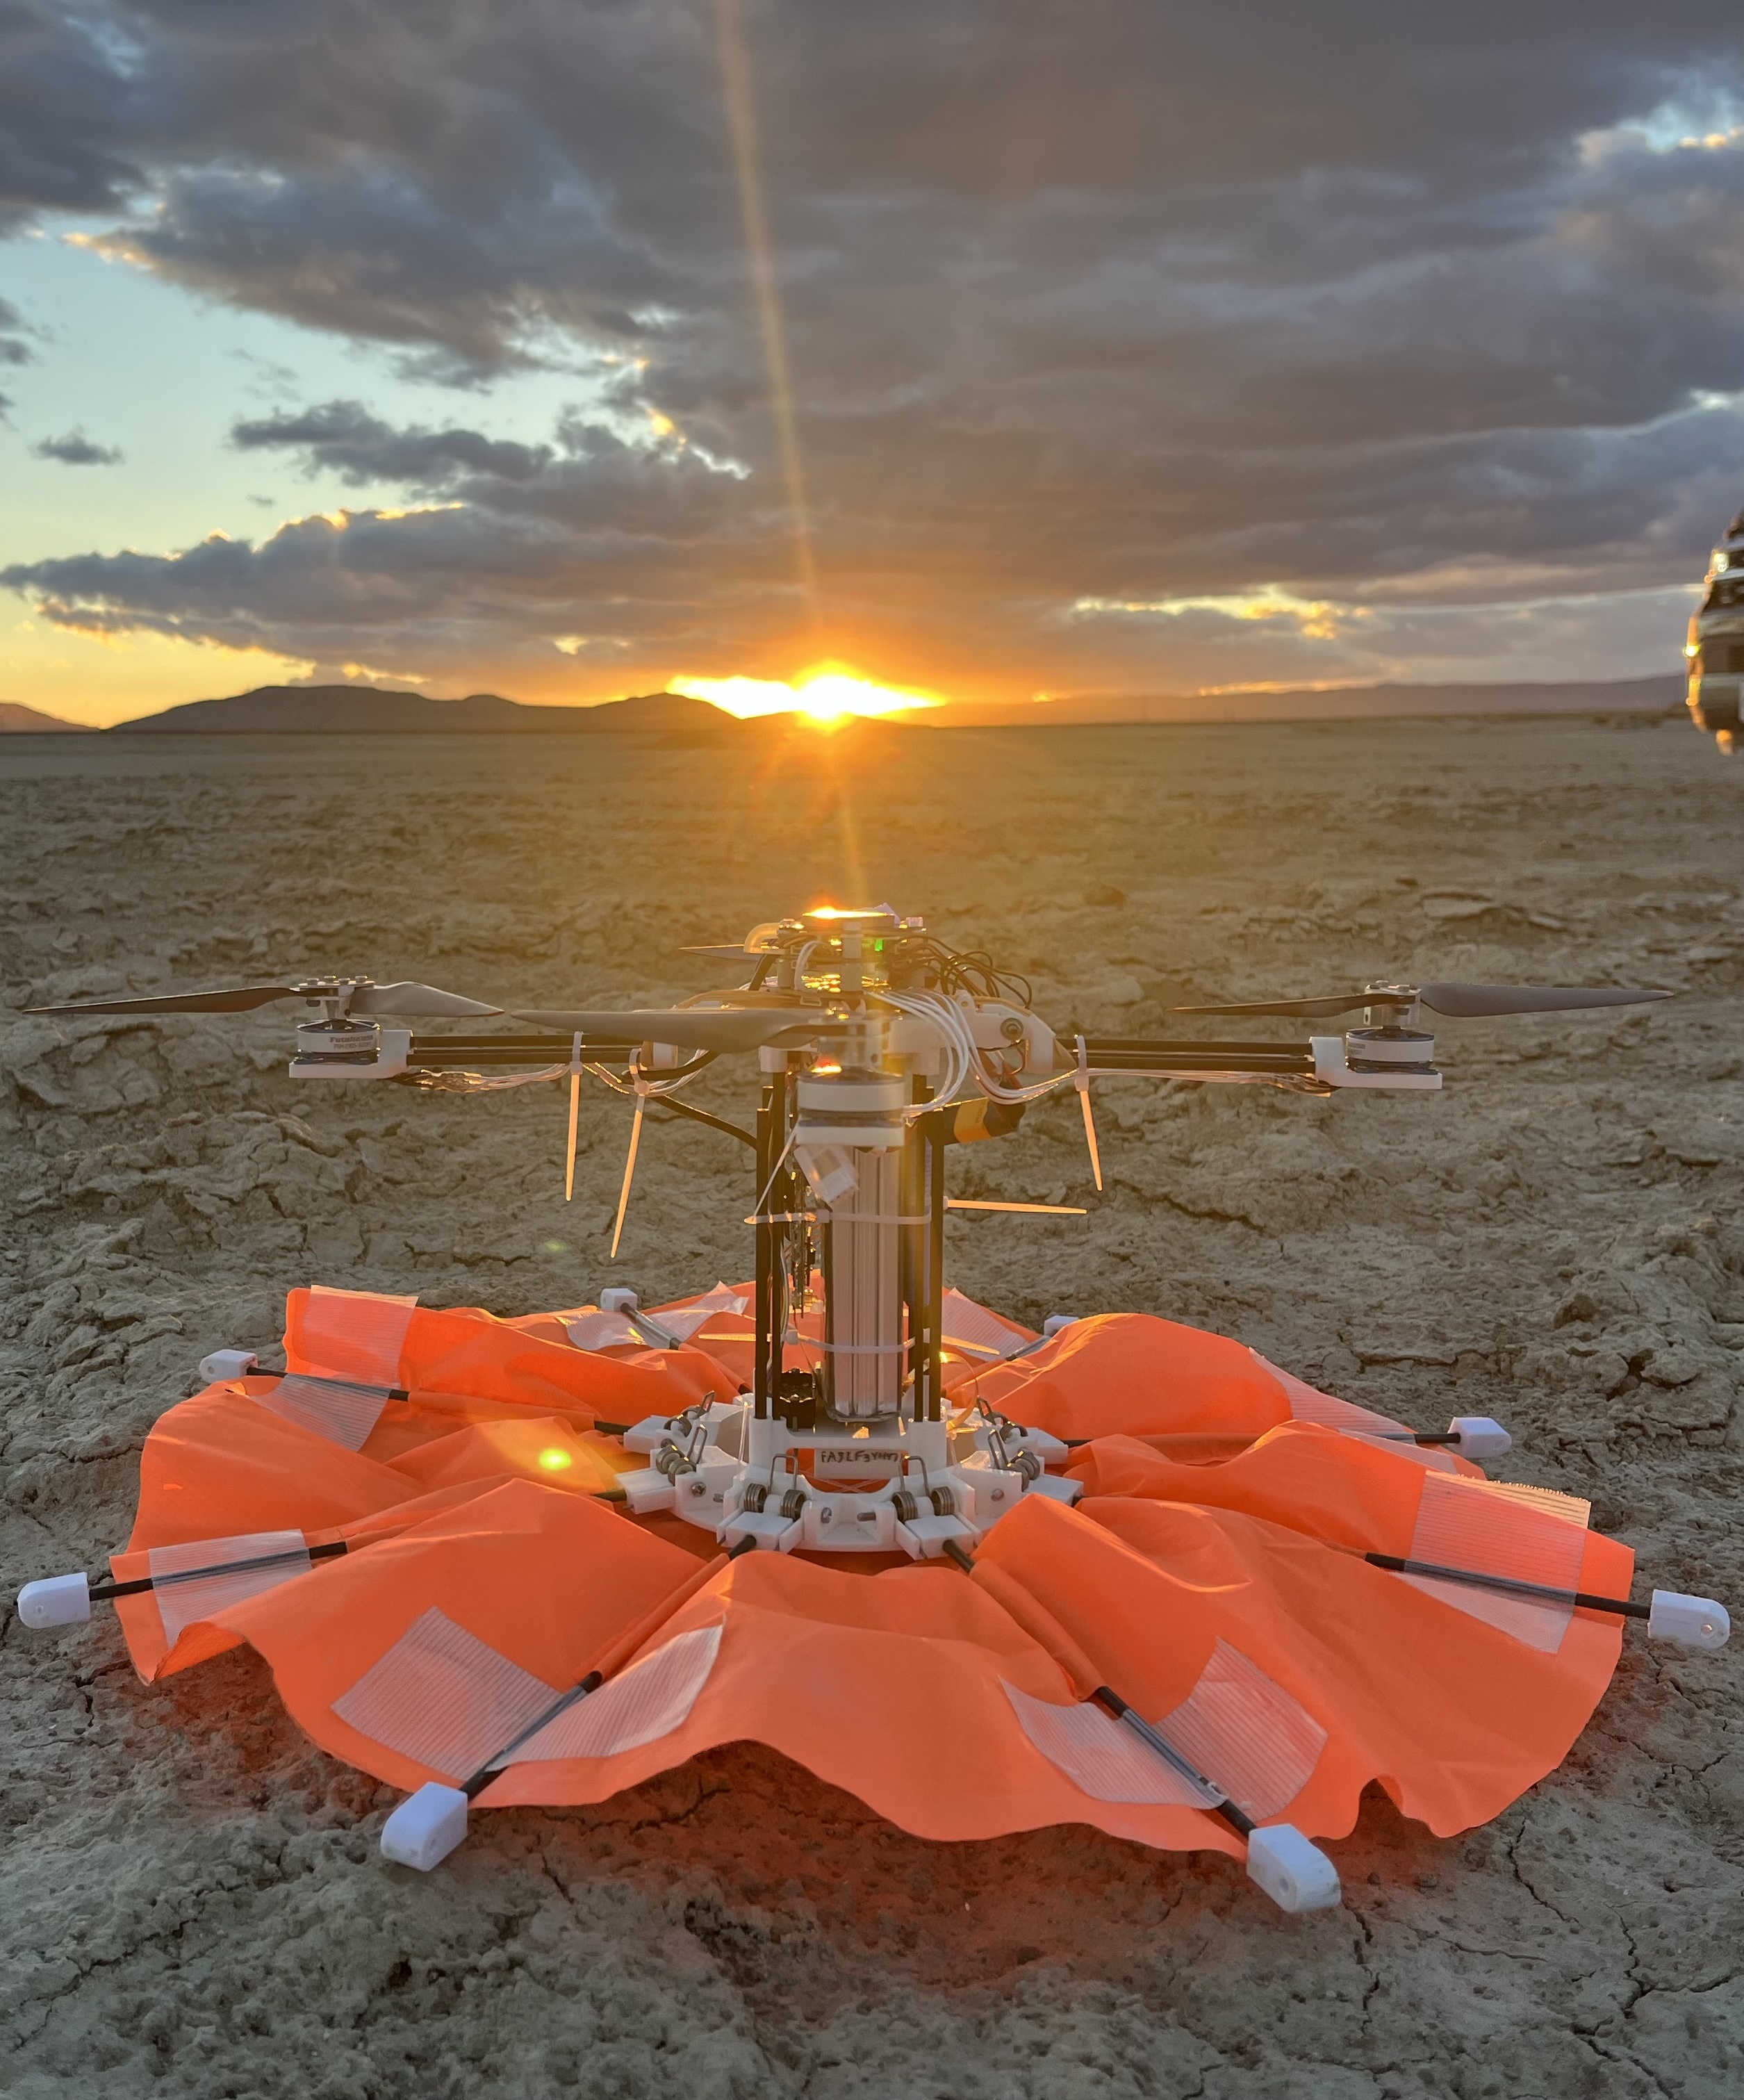
Developed a small satellite drone system from scratch in a team of eleven. Contribution: Control systems Tech: Python, Raspberry Pi zero2W etc. |
|
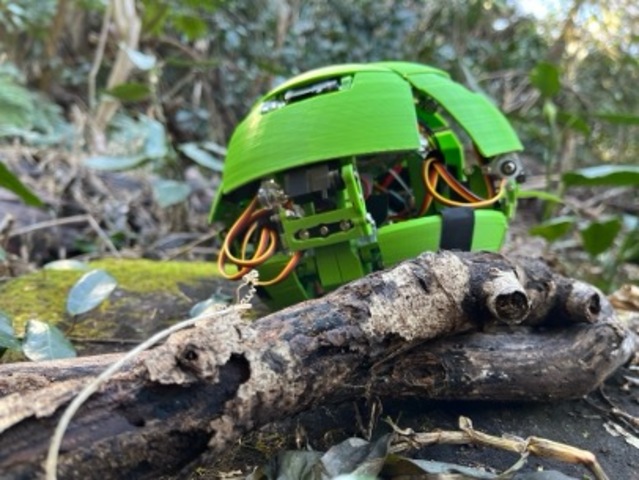
Developed an original quadruped transformable robot from scratch in a team of four. Contribution: Team lead, design, and image recognition Tech: Python, YOLOv5, 3D printing, Raspberry Pi 4B etc. |
|
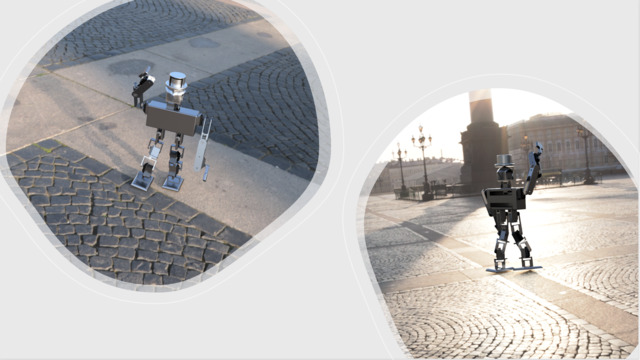
Designed and rendered a humanoid robot from scratch as the final project for a CAD class. Tech: 3DCAD (Fusion) |
|
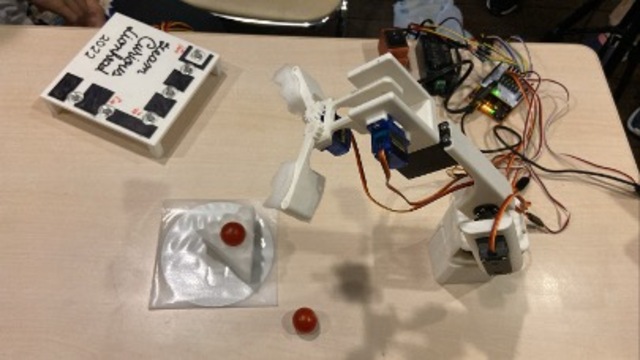
Designed the gripper and master interface for a teleoperated robot. The project was done in this course. Tech: 3D CAD (tinkercad), Keyestudio (compatible with Arduino), servo motor, 3D Printer, potentiometers, soldering |
|
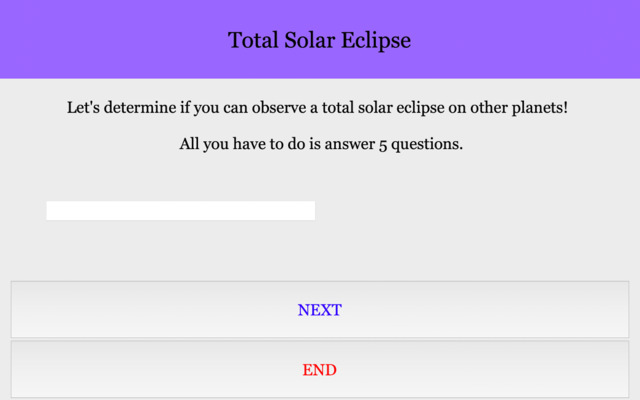
Developed an app designed to make learning STEM enjoyable, participating in an app contest hosted by The University of Electro-Communications during high school. Tech: Python, tkinter |
|
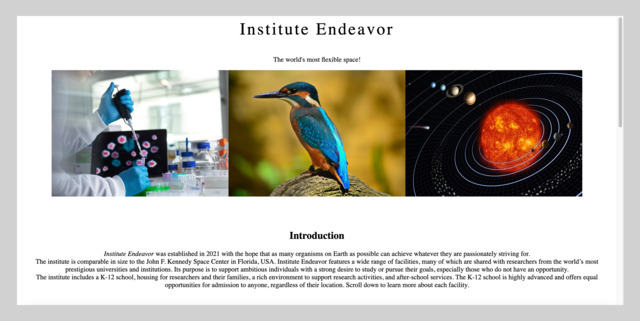
Designed and developed a website for a fictional research and education institute. (Note: All content on the webpage is purely fictional.) This was an individual project completed during high school. Tech: HTML, CSS |
ServiceReviewer: ICRA (Main Conference), CoRL (Workshop) |
Teaching
|
CertificationsHigh School Teaching License (Information Technology, Japan) |
MiscOutside of research, I enjoy composing and performing music on the piano and violin. Some of my pieces are available on YouTube and Spotify. |
The best way to reach me is by email!